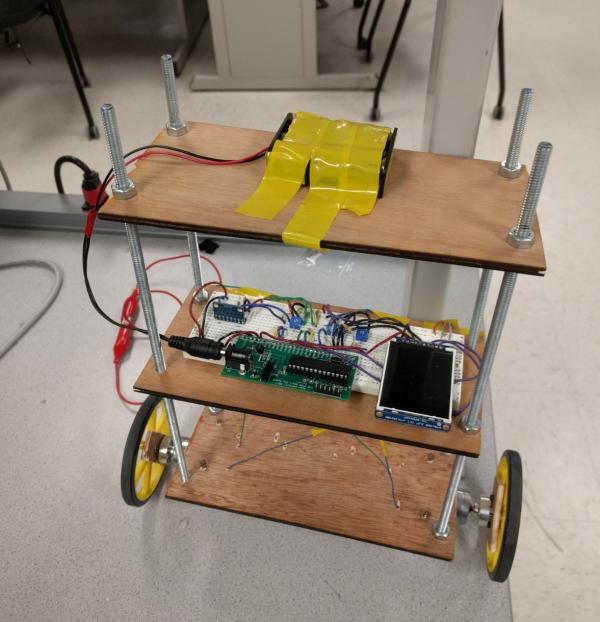
Self-Balancing Robot
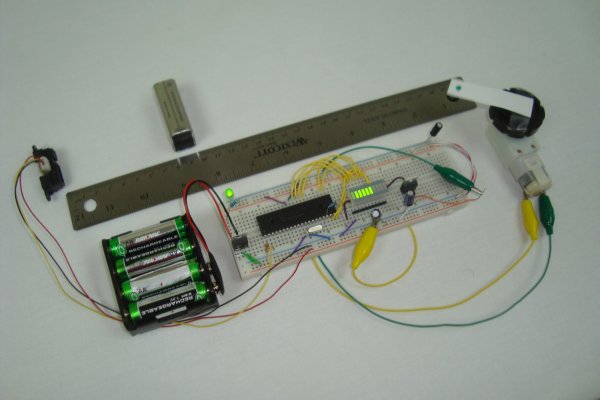
Introduction The inverted pendulum is an interesting case in the study of control systems because of its unstable nature. A pendulum is considered inverted when its center of mass is placed above its pivot point, meaning that its only equilibrium point is when its center of mass is directly above the pivot point. This is […]
Self-Balancing Robot Read More »