


This project is designed to develop as a robotic vehicle that can be controlled by a cell phones. DTMF commands from a phone send to another cell phone which is mounted on the robotic vehicle. These commands are fed to a PIC microcontroller of 8-bit architecture to operate the vehicle movement through motor interface.
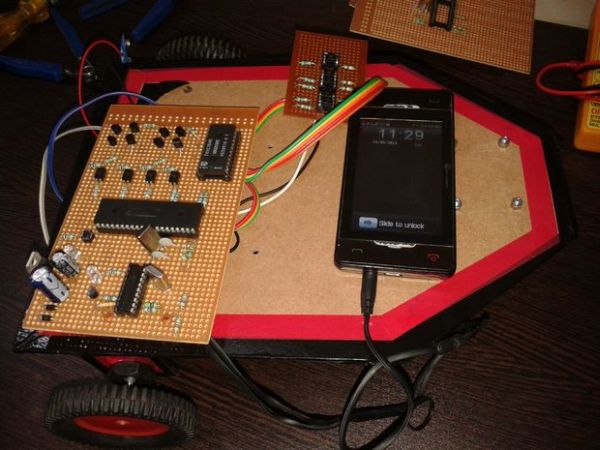
Conventionally Wireless-controlled Robots Use Rf Circuits, Which Have Limited Working Range, Limited Frequency Range and Limited Control. Use of a Mobile Phone for Robotic Control Can Overcome These Limitations. It Provides the Advantage of Robust Control, Working Range as Large as the Area of the Service Provider, No Interference with Other Controllers. Although the Appearance and Capabilities of Robot Vary Vastly, All Robots Share Feature of a Mechanical, Movable Structure Under Some Form of Control. The Control of Robot Involves Three Distinct Phases: Perception, Processing and Action. Generally, the Preceptors Are Sensors Mounted on the Robot, Processing is Done by the On-board Microcontroller or Processor, and the Task is Performed Using Motors or with Some Other Actuators. In This Project the Robot is Connected to GSM mobile (using DTMF technology) Which is Controlled by User Mobile Phone. With the Help of Commands We Can Move Our Robot in Desired Direction as Per Our Requirements. This project is Advanced version of my last project, Namely, Wireless Radio Frequency Module Using PIC Microcontroller.
Step 1: [Video] Brief Introduction & Configuration Of GSM Based Robotic Vehicle.
In this section, The video of working project is embedded, almost every (minimal) explanation is described in Video it self. e.g:
Press 1 for Move/Start/Forward,
Press 2 for Backward,
Press 3 for Moving Right,
Press 4 for Moving Left and
Press 5 for Stop.
Step 2: Components & Installation
In this section all the components are mentioned with some working & installation images. e.g:
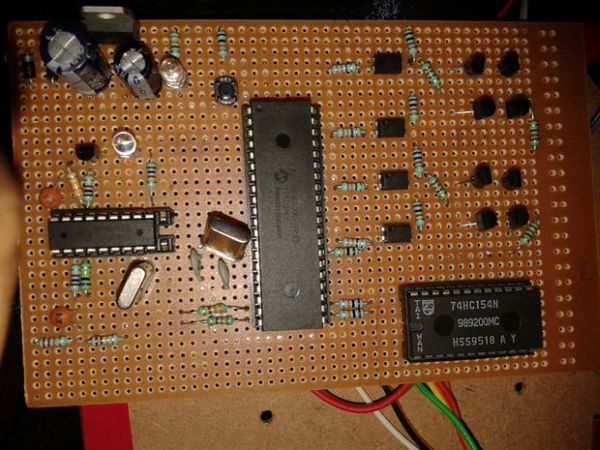
* DTMF DECODER
* 8-BIT PIC MICROCONTROLLER (16F877A)
* CELL PHONES
* DIODES
* BATTERY(6-VOLT)
* DC MOTOR
* WHEELS
* CARD BOARD
* VEHICLE'S LEGS ETC.
For more detail: GSM Based Versatile Robotic Vehicle Using PIC Microcontroller
Related projects
Real-Time CAN-Based Vehicle Monitoring System with PIC MCU
INTRODUCTION The Controller Area Network (CAN) is a robust vehicle communication bus standard that was primarily developed for automobile applications but has...
Motors & RoboticsEasy Way to Learn Robotics Using Microcontrollers: A Beginner’s Guide
The title, "Easy Way to Learn Robotics Using Microcontrollers," promises an accessible entry point for those curious about the exciting world of...
Motors & Robotics · PIC16F877AEfficient Sun-Following Robot: A Solar Tracker with Microcontroller Control
Abstract The impending global challenge of dwindling non-renewable fuel resources underscores the urgency of transitioning towards renewable energy alternatives like solar power....
Motors & RoboticsInnovative Robotics: A Comprehensive Project Exploration
A DC motor functions as an electromechanical device, translating electrical signals into mechanical movements. The rotation of the motor correlates directly with...
Motors & RoboticsAdvanced Techniques for Fault Detection, Indication, and Protection in Induction Motors
1. INTRODUCTION The impact of microcontroller usage on our daily lives is remarkable. This versatile device is now prevalent in various control...
Motors & RoboticsExploring Versatility: GSM-Based Robotic Vehicle Technology
Introduction To Robotics The term 'Robot' remains elusive, defying a precise definition due to its evolving usage. Initially, it referred to humanoid...

Ibrar Ayyub
I am an experienced technical writer holding a Master's degree in computer science from BZU Multan, Pakistan University. With a background spanning various industries, particularly in home automation and engineering, I have honed my skills in crafting clear and concise content. Proficient in leveraging infographics and diagrams, I strive to simplify complex concepts for readers. My strength lies in thorough...