motor

Team picture following project demonstration 1

Automated Ice Cream Topper

Introduction Controlled by a PIC 32, the automated ice cream topper stores individual ice cream topping preferences, outputting the user’s ideal solid, liquid, and whip cream topping amount with the push of a button. Our project demo can be viewed here: Project Demo. The automatic ice cream topper as demoed had three basic topping capabilities that

Automated Ice Cream Topper Read More »

Overall Architecture

Haptic Feedback Weathervane

Introduction When sailing a boat, one of the most important factors is the direction of the wind. If they want to keep a steady heading, sailors need to be able to dynamically adjust the direction they steer as the wind changes. Unfortunately, the ability to tell exactly which direction the wind is blowing can be

Haptic Feedback Weathervane Read More »

High level design 10

Touch-A-Sketch

Introduction For our final project, our team built a touch screen controlled Etch-A-Sketch we call Touch-A-Sketch. The Touch-A-Sketch is the first of its kind that allows users to draw on the touchscreen and sketches the drawing on the Etch-A-Sketch by controlling the knobs on either corner of the toy. There are four main components that

Touch-A-Sketch Read More »

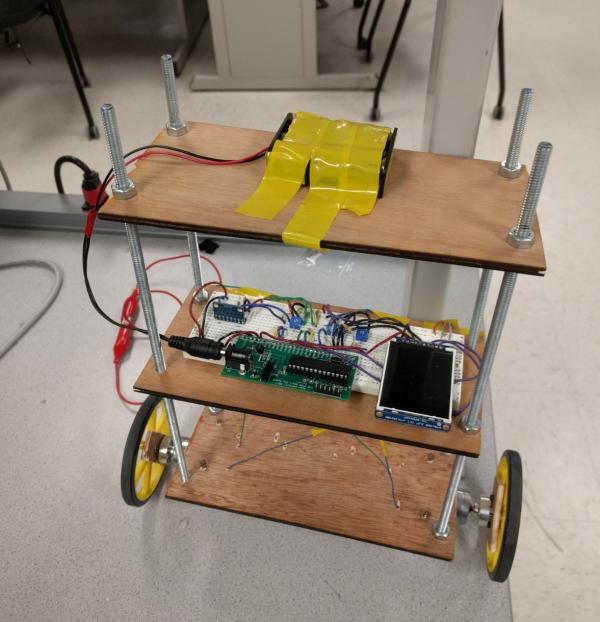
An image of the final version of our robot.

Self-Balancing Robot

Introduction The inverted pendulum is an interesting case in the study of control systems because of its unstable nature. A pendulum is considered inverted when its center of mass is placed above its pivot point, meaning that its only equilibrium point is when its center of mass is directly above the pivot point. This is

Self-Balancing Robot Read More »

Top Level Block Diagram

Bot Ross

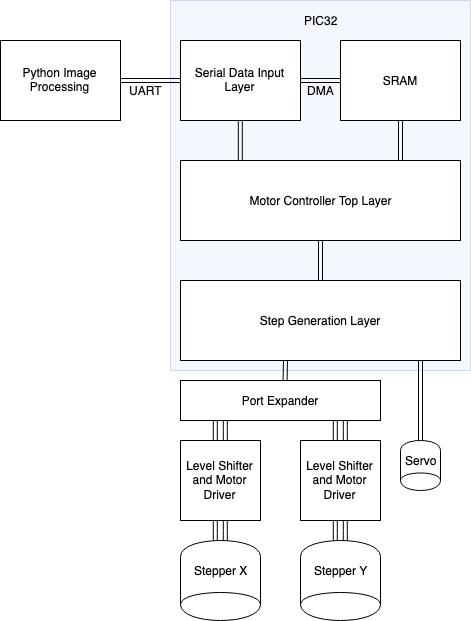
Introduction Bot Ross is a moderately sized 2-D contour plotter, capable of drawing images with a resolution of roughly 1 mm. The design consists of a pen with degrees of freedom in the x and y directions, actuated using threaded rods controlled by two stepper motors. The pen may be raised or lowered using a

Bot Ross Read More »

The Microchipoptera Project

The Microchipoptera Project

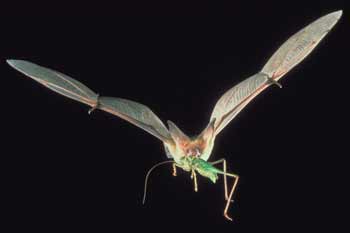
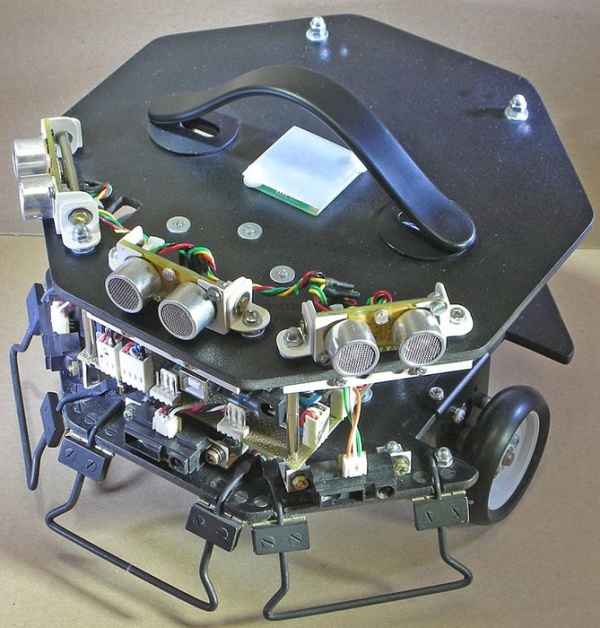
Motivation:     The echolocating bat is a wonderful animal that is unique in so many different ways:  it is the only truly flying mammal, it can use air-coupled sonar to navigate in complete darkness while flying, it can allow its body temperature to drop to as low as 1degC (torpor) to save energy, and it

The Microchipoptera Project Read More »

How to Build a Self Navigating Robot

How to Build a Self Navigating Robot

This is a detailed tutorial on how to realize a robot starting from scratch, and giving it the ability to navigate autonomously in an unknown environment. All the typical arguments involved with robotics will be covered: mechanics , electronics and programming . The whole robot is designed to be made by anyone at home without professional (i.e. expensive) tools and equipment.

How to Build a Self Navigating Robot Read More »