


Summary of PRECISION CNC MOTION CONTROL UNIT ENCODER, DRIVER INTERFACE PIC16F877
This project designs and implements a high-precision CNC motion control system based on a PIC16F877 microcontroller, featuring RS232 PC connectivity, a current-regulated DC motor power module, current regulator, encoder interface and motion controller. The work includes assembly source code for MPLAB IDE and focuses on precise multi-axis drive control suitable for industrial applications.Parts used in the High Precision CNC Motion Control Unit:
- PIC16F877 microcontroller
- RS232 interface components (for PC connection)
- DC motor power module
- Current regulator
- Motion controller circuitry
- Encoder and encoder interface
- Driver interface circuitry
- Power supply components
- Serial communication wiring (e.g., connectors, cables)
- MPLAB IDE compatible assembly source code
CNC control circuit PIC16F877 microcontroller used in the project’s RS232 PC connection to all floors described separately (English) source: Assembly shared MPLAB IDE software. HIGH PRECISION CNC MOTION CONTROL This thesis focuses on the... Electronics Projects, Precision CNC Motion Control Unit Encoder, Driver Interface PIC16F877 "microchip projects, microcontroller projects, pic16f877 projects, "
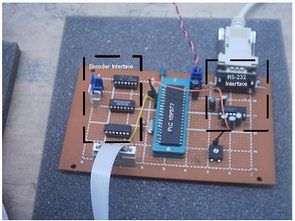
CNC control circuit PIC16F877 microcontroller used in the project’s RS232 PC connection to all floors described separately (English) source: Assembly shared MPLAB IDE software.
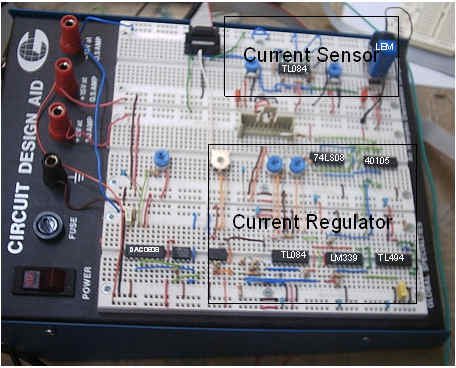
HIGH PRECISION CNC MOTION CONTROL
This thesis focuses on the design of an electrical drive system for the purpose of high precision motion control. A modern electrical drive is usually equipped with a current regulated voltage source along with powerful motion controller system utilizing one or more micro-controllers and/or digital signal processors (DSPs).
That is, the motor drive control is mostly performed by a dedicated digital-motion controller system. Such a motor drive mostly interfaces with its host processor via various serial communication protocols such as Profibus, CAN+, RS-485 etc. for the purpose of receiving commands and sending out important status/control signals. Considering that the motor drives lie at the heart of every (multi-axis) motion control system, the aim of this thesis is to explore the design and implementation of a conventional DC motor drive system suitable for most industrial applications that require precision and accuracy.
To achieve this goal, various underlying control concepts and important implementation details are rigorously investigated in this study. A low power DC motor drive system with a power module, a current regulator and a motion controller is built and tested. Several design revisions on these subsystems are made so as to improve the overall performance of the drive system itself. Consequently, important “know-how” required for building high performance (and high power) DC motor drives is gained in this research.
Source: etd.lib.metu.edu.tr CNC circuit alternative link: precision-cnc-motion-control-unit-encoder-driver-interface-pic16f877.rar
- What microcontroller is used in the project?
The project uses a PIC16F877 microcontroller. - How does the project connect to a PC?
It uses an RS232 PC connection as described in the project. - Does the project include source code?
Yes, assembly source code for MPLAB IDE is provided. - What kind of motor drive is implemented?
A conventional DC motor drive system with a power module and current regulation is implemented. - What interfaces are included for position sensing?
The project includes an encoder and encoder interface for position sensing. - Can the drive system handle multi-axis motion control?
The thesis targets multi-axis motion control applications and discusses interfacing via serial protocols. - What communication protocols are mentioned for motor drive interfacing?
Serial protocols such as Profibus, CAN+, and RS-485 are mentioned as typical interfaces; RS232 is used for PC connection in this project. - What are the main subsystems built and tested?
The main subsystems are a power module, a current regulator, and a motion controller.
Related projects
PIC16F877 Driving LCD in 4-Bit Mode using PIC16F877 with Proteus Simulation
Introduction This microcontroller project shows how a PIC16F877 can drive an LCD display using 4-bit mode inside a Proteus simulation.The project demonstrates...
Programmers & ICSP · PIC16F877AEPE PIC/LCD Demo using PIC16F877 with Proteus Simulation
IntroductionThe EPE PIC/LCD Demo is a classic microcontroller project that demonstrates how a PIC16F877 can fully control a PG12864F graphical LCD.Designed as...
Motors & Robotics · PIC16F877AEfficient Sun-Following Robot: A Solar Tracker with Microcontroller Control
Abstract The impending global challenge of dwindling non-renewable fuel resources underscores the urgency of transitioning towards renewable energy alternatives like solar power....
Motors & RoboticsReal-Time CAN-Based Vehicle Monitoring System with PIC MCU
INTRODUCTION The Controller Area Network (CAN) is a robust vehicle communication bus standard that was primarily developed for automobile applications but has...
Motors & RoboticsEasy Way to Learn Robotics Using Microcontrollers: A Beginner’s Guide
The title, "Easy Way to Learn Robotics Using Microcontrollers," promises an accessible entry point for those curious about the exciting world of...
Motors & RoboticsInnovative Robotics: A Comprehensive Project Exploration
A DC motor functions as an electromechanical device, translating electrical signals into mechanical movements. The rotation of the motor correlates directly with...

Ibrar Ayyub
I am an experienced technical writer holding a Master's degree in computer science from BZU Multan, Pakistan University. With a background spanning various industries, particularly in home automation and engineering, I have honed my skills in crafting clear and concise content. Proficient in leveraging infographics and diagrams, I strive to simplify complex concepts for readers. My strength lies in thorough...