robot

Video Project Development in the Midst of an Impromptu Online Semester

Video Project Development in the Midst of an Impromptu Online Semester

Receiving robot parts in the mail was an unexpected conclusion to the Winter 2020 semester for students. However, when faced with a unique situation, innovative solutions were required, and the instructors of EECS 373: Introduction to Embedded System Design rose to the challenge. With the sudden transition to online learning in March due to the […]

Video Project Development in the Midst of an Impromptu Online Semester Read More »
External Input and Output Signals

Microcontroller Implementation of a Small Robot Arm Controller

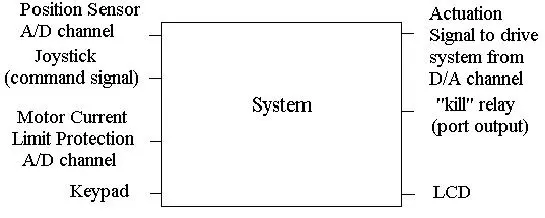
Our senior project aims to design and develop assembly language for a small robot arm assembly controller, utilizing an enhanced 8051 microcontroller (80535). In addition to the controller’s software, we will design and construct the microcontroller interface circuitry. Our investigation will focus on incorporating safety features, such as motor current limit protection and motor disable

Microcontroller Implementation of a Small Robot Arm Controller Read More »

​Bluetooth Controlled Obstacle Avoidance Robot Car Using PIC32 Microcontroller

​Bluetooth Controlled- Obstacle Avoidance Robot Car Using PIC32 Microcontroller

“Robot-Car: Design Fused with Obstacle Avoidance Technology” Recently, there is an intensive research undertaken in the field of intelligence robotics and autonomous mobile robot applications. Through the this project we wanted to explore this field by building a robot car that can potentially avoid the obstacles. This is a user controlled robot car that has

​Bluetooth Controlled- Obstacle Avoidance Robot Car Using PIC32 Microcontroller Read More »

Flex Sensor

HAND-GESTURE CONTROLLED ROBOT

High-Level Design The project can be logical separated into two different components: the glove and the car. The glove is the main way the user will interact with the car. Several fingers on the glove are outfitted with flex sensors to capture events when the user curls or uncurls figers. There are a combination of

HAND-GESTURE CONTROLLED ROBOT Read More »

Image Processing Program

Rubik’s Cube Solving Robot

Introduction Our project was creating a rubiks cube solving robot that utilized image processing, Kociemba’s algorithm, and servos acting as claws/arms to turn the cube. We had a goal of being completely self contained and would not need any human interaction after the initial cube placement. In order to achieve this, we needed a way

Rubik’s Cube Solving Robot Read More »

An image of the final version of our robot.

Self-Balancing Robot

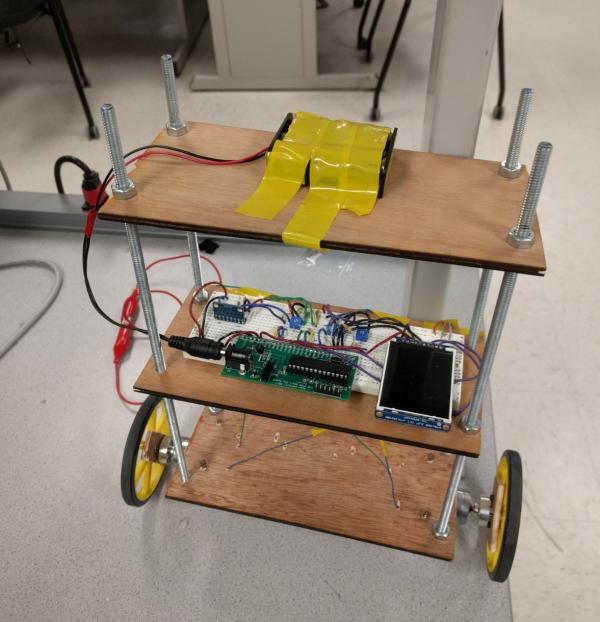
Introduction The inverted pendulum is an interesting case in the study of control systems because of its unstable nature. A pendulum is considered inverted when its center of mass is placed above its pivot point, meaning that its only equilibrium point is when its center of mass is directly above the pivot point. This is

Self-Balancing Robot Read More »